RealWorld Unveils DexBench to Benchmark Robot Hand Dexterity
Nvidia-backed RealWorld has released DexBench, a benchmark that scores humanoid robots on precise five-fingered hand tasks such as plugging connectors and stacking plates.
 SUMO· the number puzzle
 Dialo· learn languages by speaking
 ediviewer· read EDI files like documents
 giftdetect· the right gift in minutes
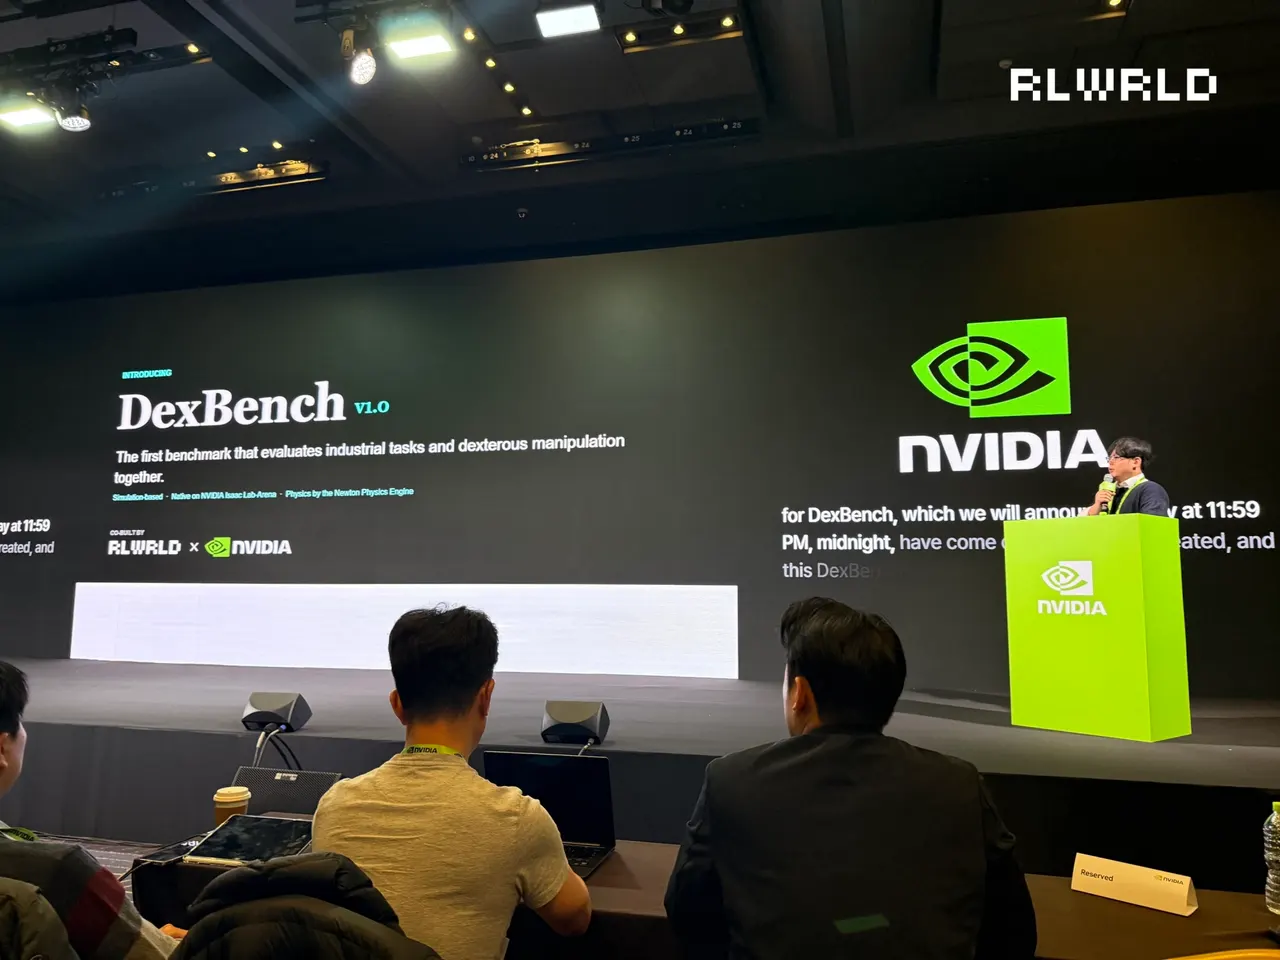
RealWorld, a Korean physical-AI company that builds robot foundation models, has unveiled DexBench, a benchmark for measuring how well humanoid robots handle objects with five-fingered hands. CEO Joong-Hee Ryu's company presented it on November 9 at Nvidia AI Day Seoul 2026 at Coex. RealWorld also confirmed that Nvidia, which announced the plan the same day, intends to invest in the company.
Fifteen tasks across four industries
DexBench is the first result of work RealWorld began with Nvidia in June to build evaluation standards and data standards for precise hand manipulation. Earlier robot benchmarks mostly tested simple pick-and-place jobs on a tabletop. DexBench instead reproduces 15 tasks in four settings: retail, logistics, assembly and hotel food and beverage. Examples include placing products, unloading items from roll cages, plugging in connectors, tightening screws, stacking plates and pouring liquids. Objects and equipment in the simulation follow real product specifications.
Scoring covers task success rate and generalization, meaning whether a robot still succeeds with objects, physical properties or layouts it did not see in training. The benchmark is built on Nvidia's open-source Isaac Lab-Arena, a tool for large-scale simulated evaluation of robot control models, and the open-source Newton physics engine. These let it reproduce finger-object contact, deformable objects and moving equipment.
Partners and next steps
N.Lite, SpaceAI and PhysicsSimLab supplied 3D data and environments. Overseas robotics firms including Genesis AI and Mimic Robotics are testing a pre-release version. RealWorld plans to publish the code, evaluation environments, simulation and training data, baseline results and a leaderboard so researchers and developers can compare models on the same terms. The first baseline was measured with RLDX 1.1, the next version of RealWorld's own foundation model.
The company will strengthen checks that compare simulation results with real-robot performance and add support for more robots and hand types.
Separately, Nvidia said at an AI startup partnership forum held with Korea's science ministry that it plans to invest in RealWorld, Motif Technologies and Upstage. Amounts were not disclosed. RealWorld will use the funds to refine its foundation model and widen deployment in industrial sites. Ryu said objective measurement of precise manipulation is needed for robot AI to move into real workplaces.
Apps worth a look
SUMO: the number puzzleTap the right tiles, add them up, hit the target. Easy to learn, hard to master. Free, for all ages.
Dialo: learn languages by speakingTalk to an AI conversation partner; every sentence comes back corrected and explained in your language. 9 languages, A1 to C2.
ediviewer: read EDI files like documentsOpen EDIFACT and X12 messages, see every segment explained, convert to JSON/XML, export PDF and Excel. Runs locally, no upload.
giftdetect: the right gift in minutesPick who it is for, the occasion and their personality. The search engine reads product descriptions from local shops and ranks what fits. Free, no sign-up.
More from this day
See all →
Samsung Tests Paid Galaxy AI Premium Subscription for Phones

Sega Fave Cyberattack Knocks Arcade Machines Offline Across Japan
Shinhan and Hana Bank Offer Minimal Relief After Data Breach
Korea's FTC Flags Competition Concerns in Naver Financial–Dunamu Deal
More in: Startups
See all →
Edgevana secures $700m in Nvidia compute deals for AI
SoftBank and Grab Plan $1.8 Billion AI Infrastructure in Malaysia